Daniel Engelsman

I am a Ph.D. researcher at the Autonomous Navigation and Sensor Fusion Lab (ANSFL), led by Prof. Itzik Klein at the University of Haifa.
My research focuses on coupled estimator-controller dynamics and adaptive planning horizons to build lean, robust Guidance, Navigation, and Control (GNC) pipelines for self-contained aerial robotics.
In my belief space, everything in GNC flows from the state estimator: if your filter drifts, your controller panics, and your planner fails. I build tightly coupled, adaptive, and real-time bulletproof pipelines to—Make GNC Great Again !
Two INDI-based controllers; nominal (brown, baseline) vs. Estimation-Aware (green, ours), competing on a tilted lemniscate trajectory.
Open Questions I’m Exploring
-
Uncertainty Propagation Across Time Scales: How does state estimation uncertainty propagate across multi-rate GNC layers? Can we establish spatiotemporal mappings that inform every level of the hierarchy without bottlenecking trajectory planners?
-
High-Fidelity Sim-to-Real Generalization: How can photorealistic rendering and high-fidelity physics engines enable zero-shot deployment under unmodeled environmental interactions? Can domain randomization combined with physics-informed learning guarantee bounded tracking error during real-world execution?
-
Guaranteed Safety Under Active Degradation: How do we construct dynamic safety certificates when sensor availability and noise statistics degrade unannounced? Can we bound state extrapolation across platform dynamics and environmental disturbances during extreme dead reckoning?
news
| Sep 21, 2026 | Head a great time in the International Micro Air Vehicle Conference and Competition (IMAV 2026) in Strasbourg! Inspiring to connect with fellow micro-aerial robotics & GNC researchers, watch the impressive flight competitions, and enjoy the French cuisine along the way! 🇫🇷 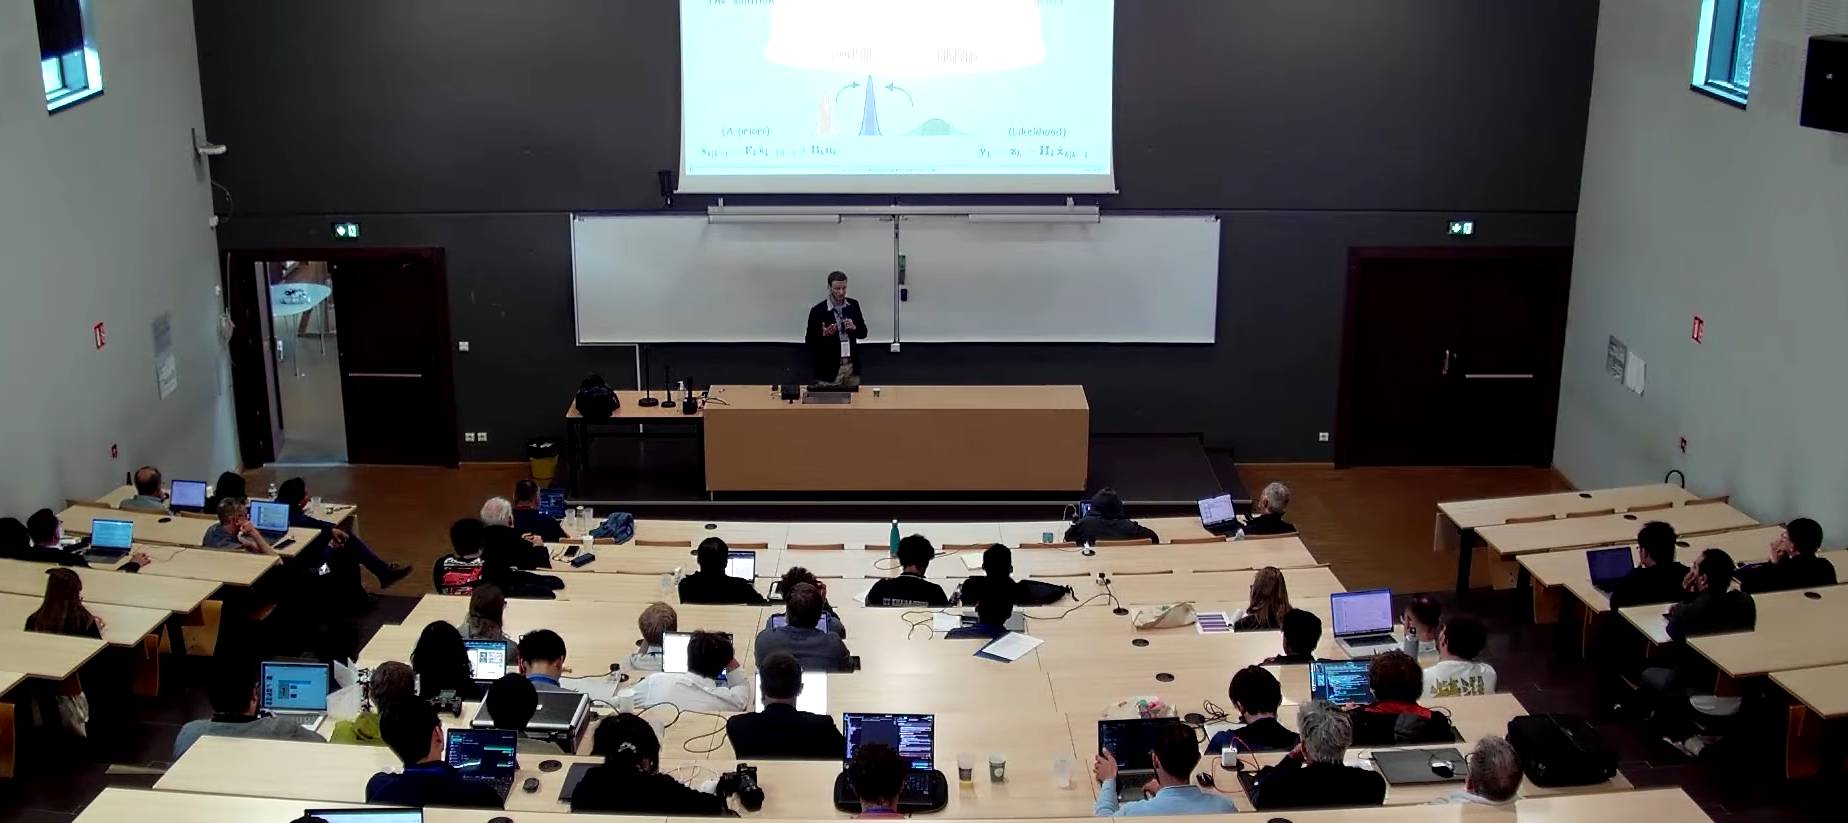 |
|---|---|
| Jul 29, 2026 | Attended the IEEE RAS Summer School on Multi-Robot Systems 2026! It was an incredible experience connecting in person with leading GNC researchers and getting to know the exceptional team led by Prof. Martin Saska at CTU in Prague. 🇨🇿 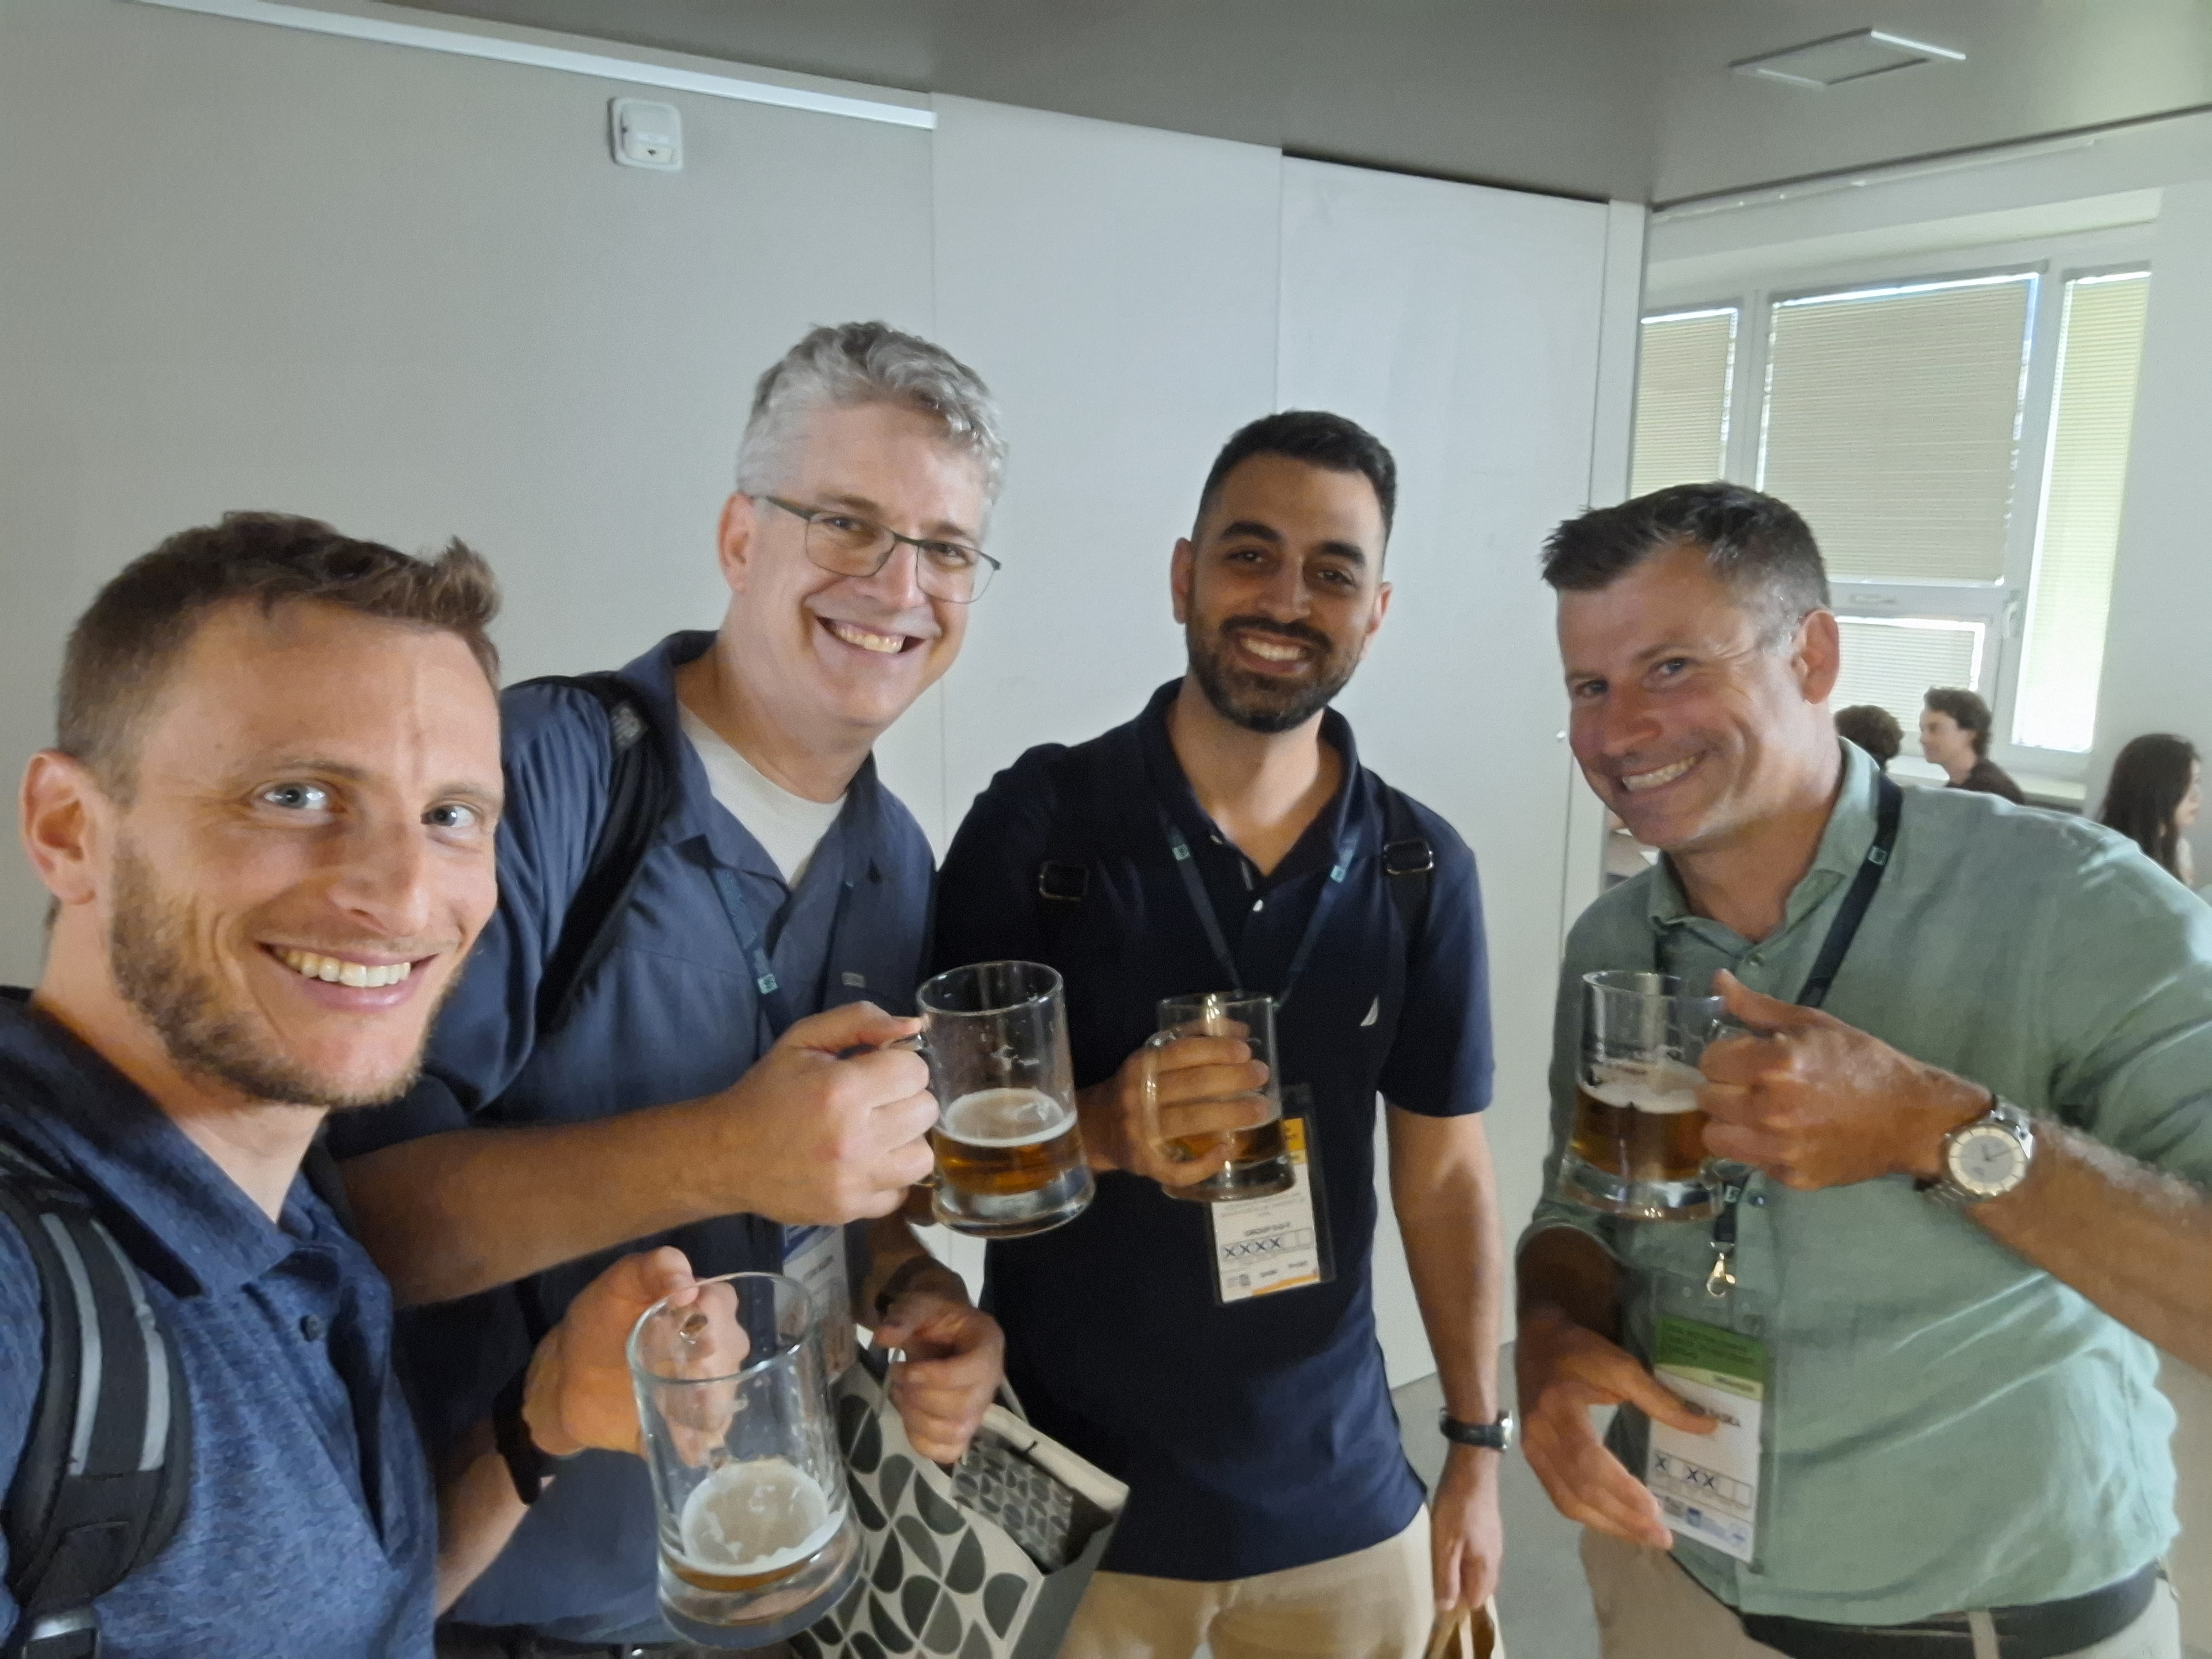 |
| May 02, 2026 | Attended EuroGNC 2026 in Madrid! It was a fantastic experience connecting with fellow GNC researchers, discuss state-of-the-art flight control and navigation, and catch up over local tapas. Reach out if you’d like to meet up! 🇪🇸 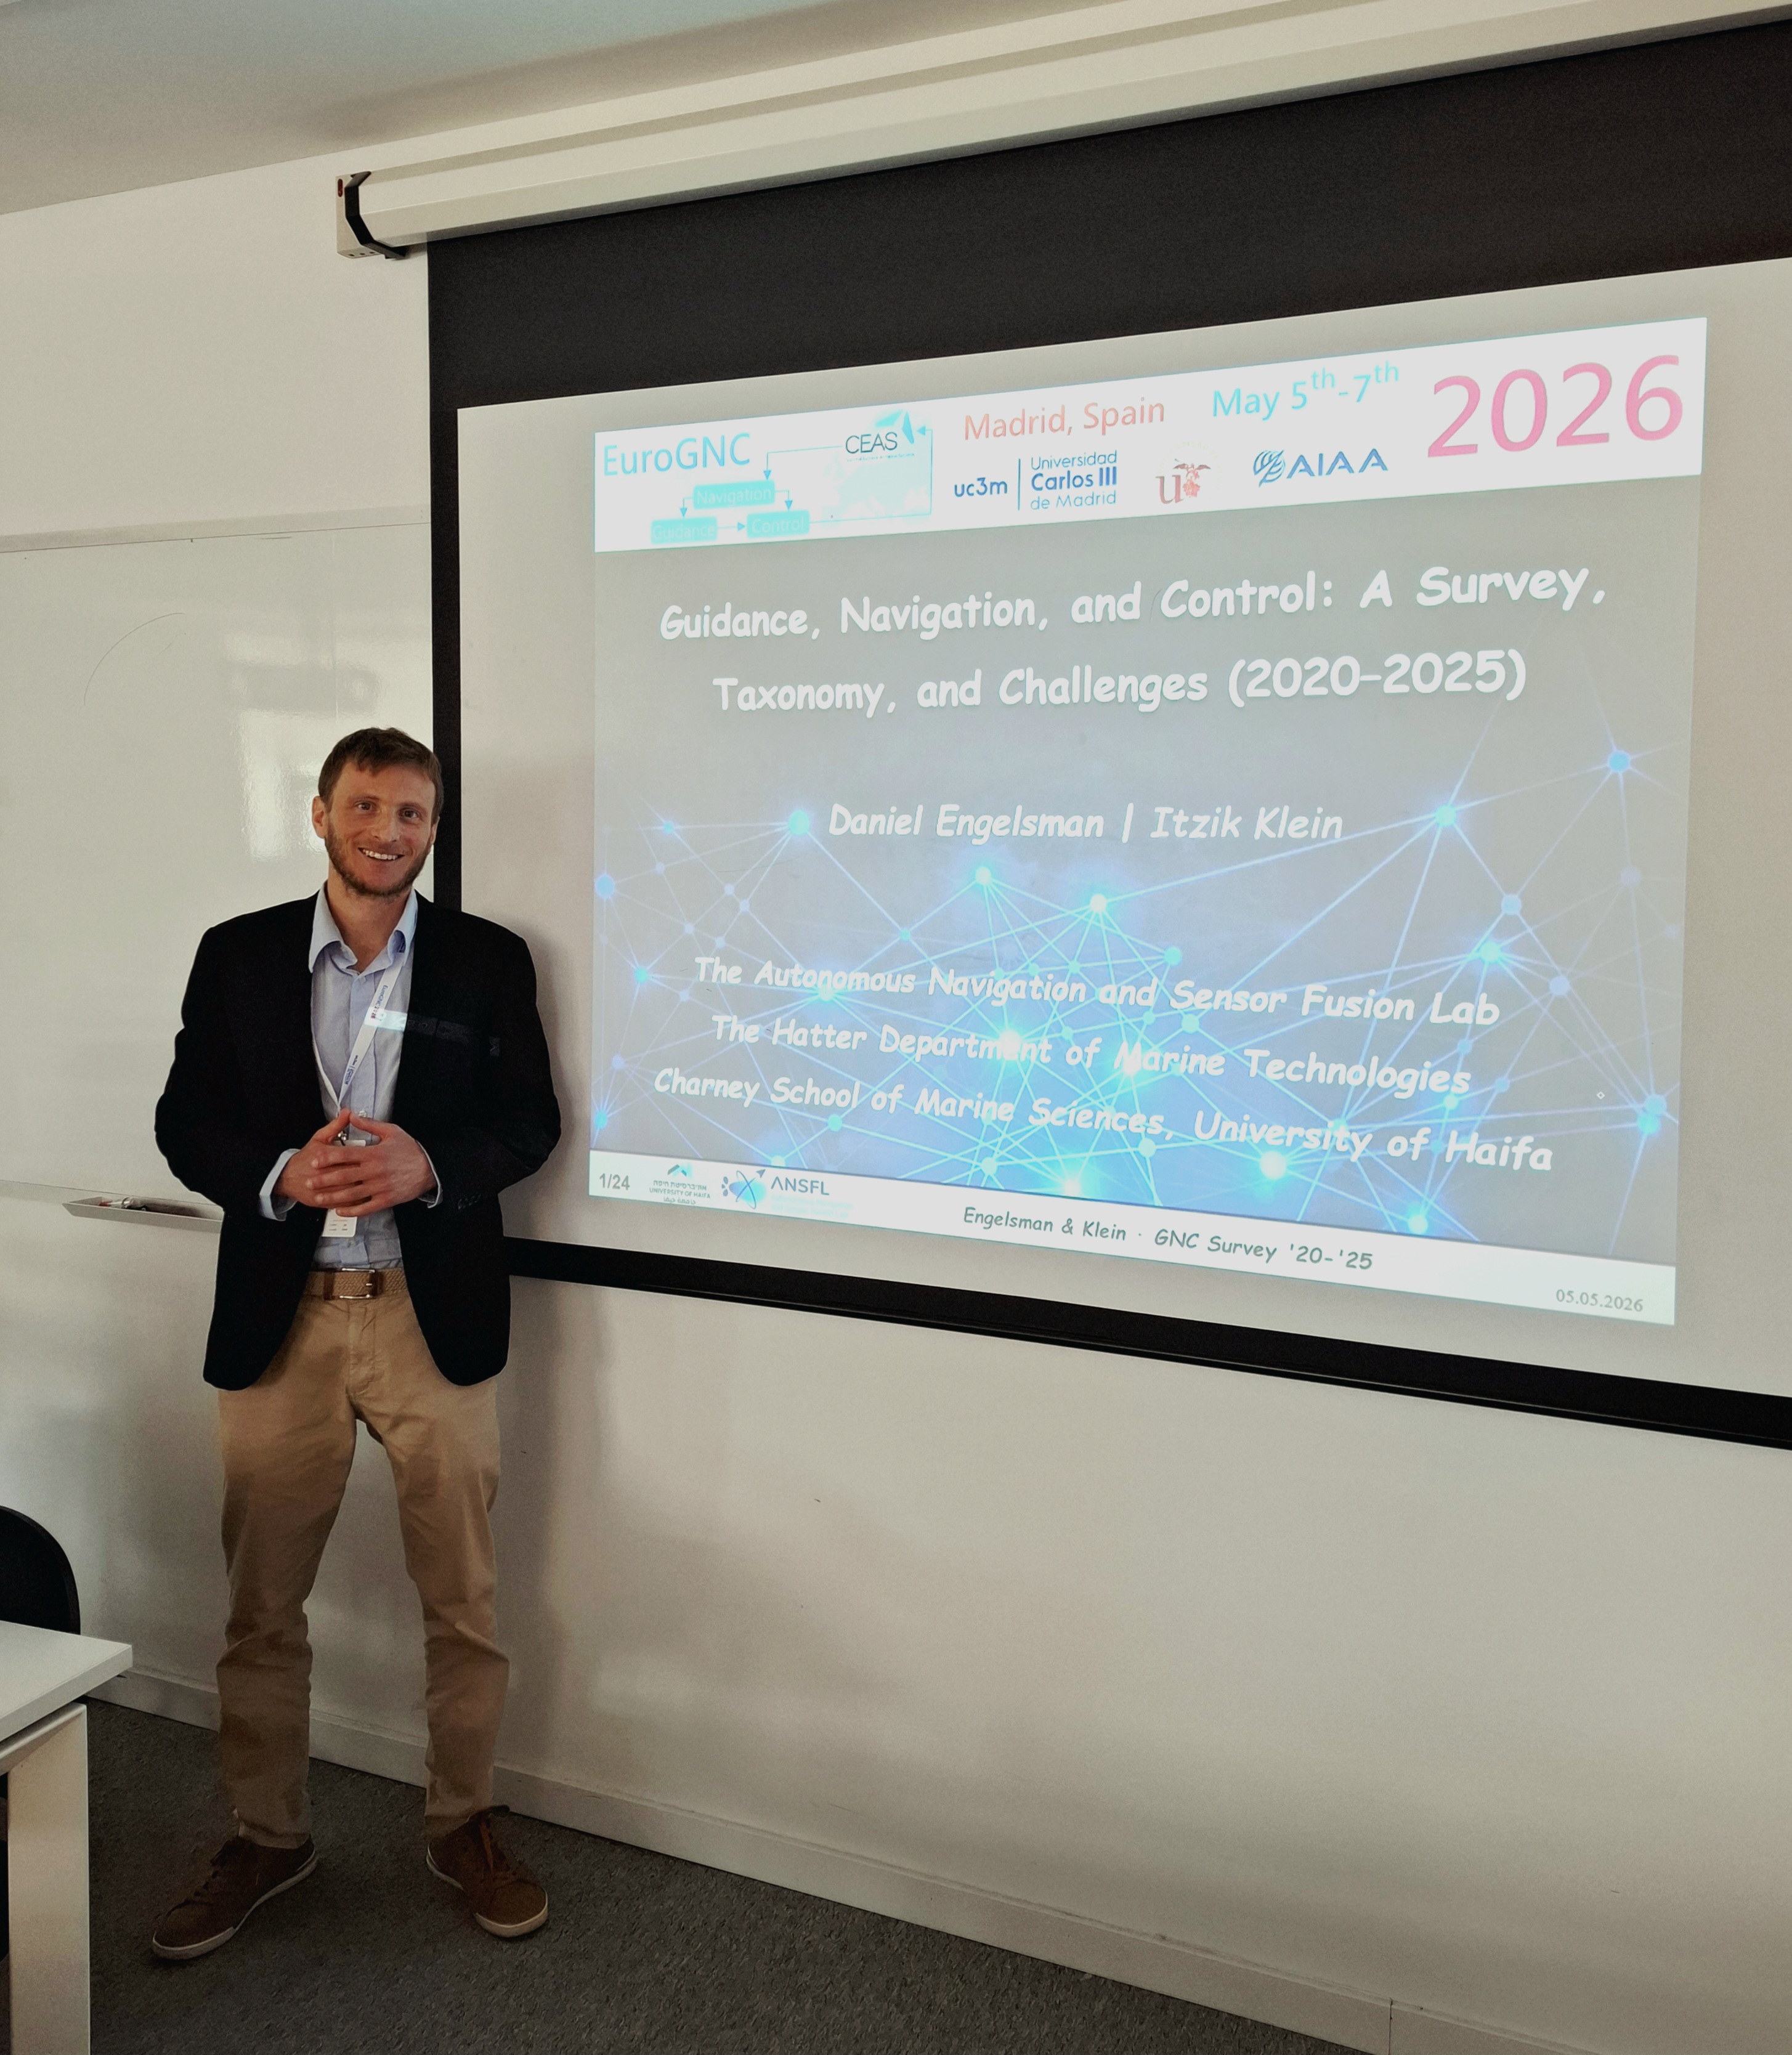 |
| May 25, 2025 | Won 1st place at the inaugural Haifa Artificial Intelligence (HiAI) conference, organized by the Data Science Research Center (DSRC) at the University of Haifa! Great experience presenting our GNC work and connecting with the AI research community. 🏆 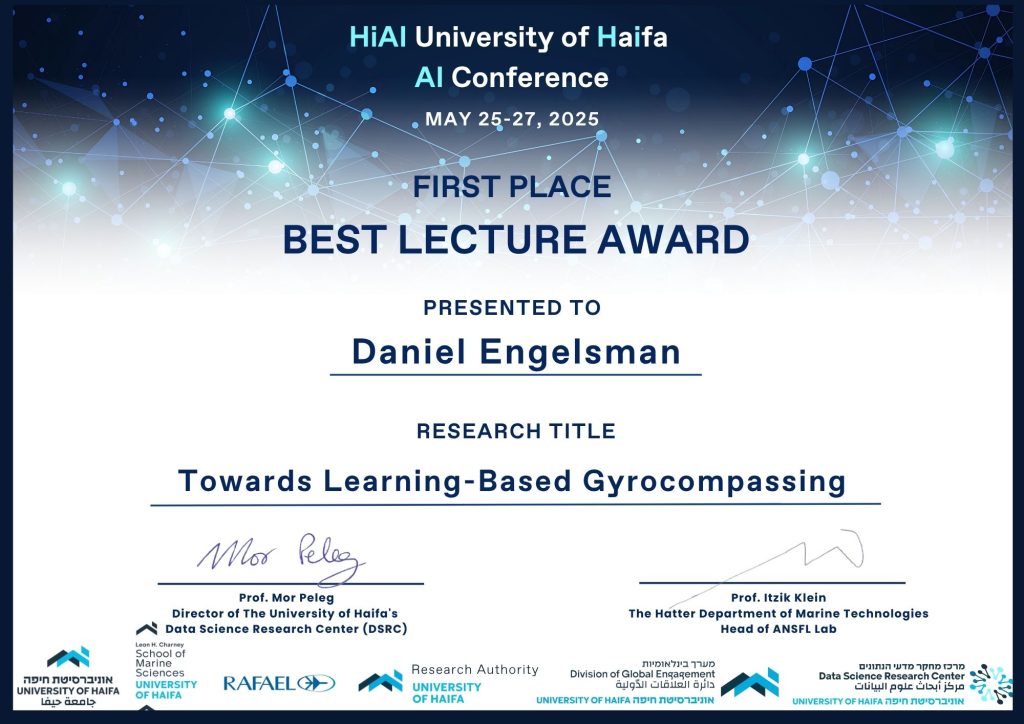 |
| Jul 08, 2024 | Presented our latest learning-based in autonomous navigation at The Israel Navigation Workshop and Exhibition (INWE24)! It was a fantastic opportunity to engage with leading experts across industry and academia. 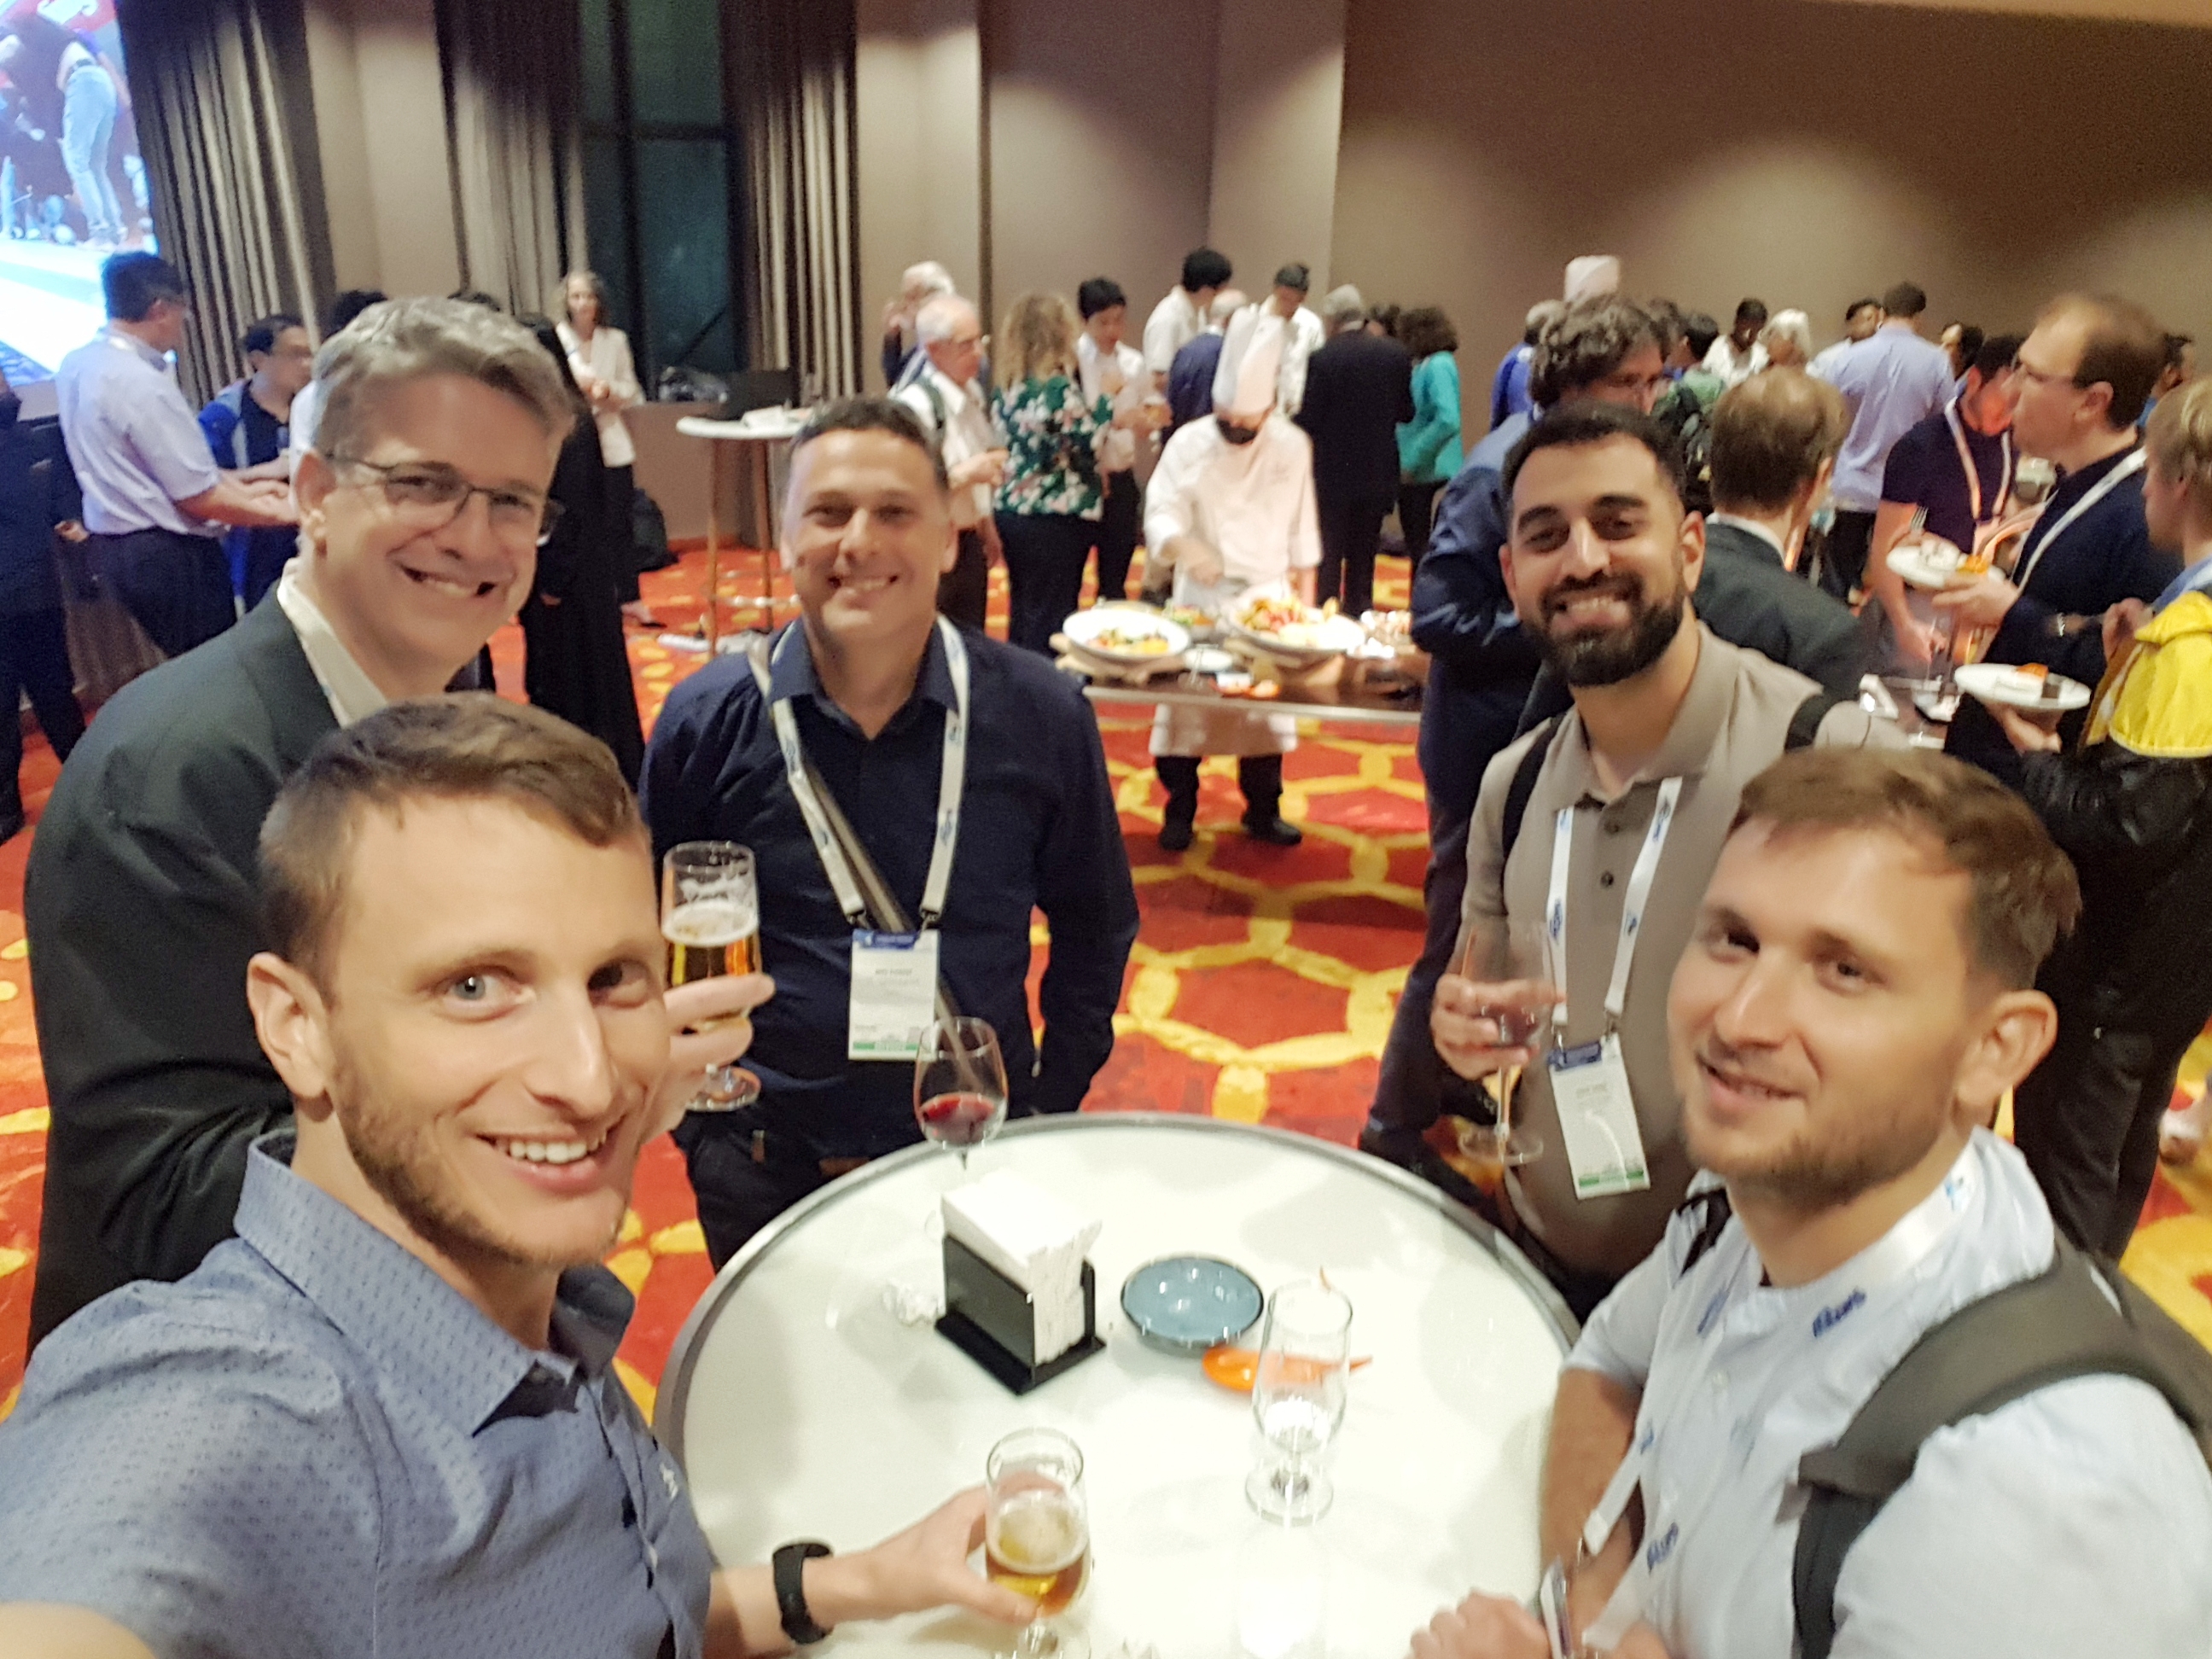 |
selected publications
- arXivRevisiting Certainty Equivalence: The Structural Coupling Between Estimation and Control in Underactuated Nonlinear SystemsarXiv preprint arXiv:2607.07276, 2026
- TAESC-ZUPT: Stationarity-Aided Aerial HoveringIEEE Transactions on Aerospace and Electronic Systems, 2026
- EAAI